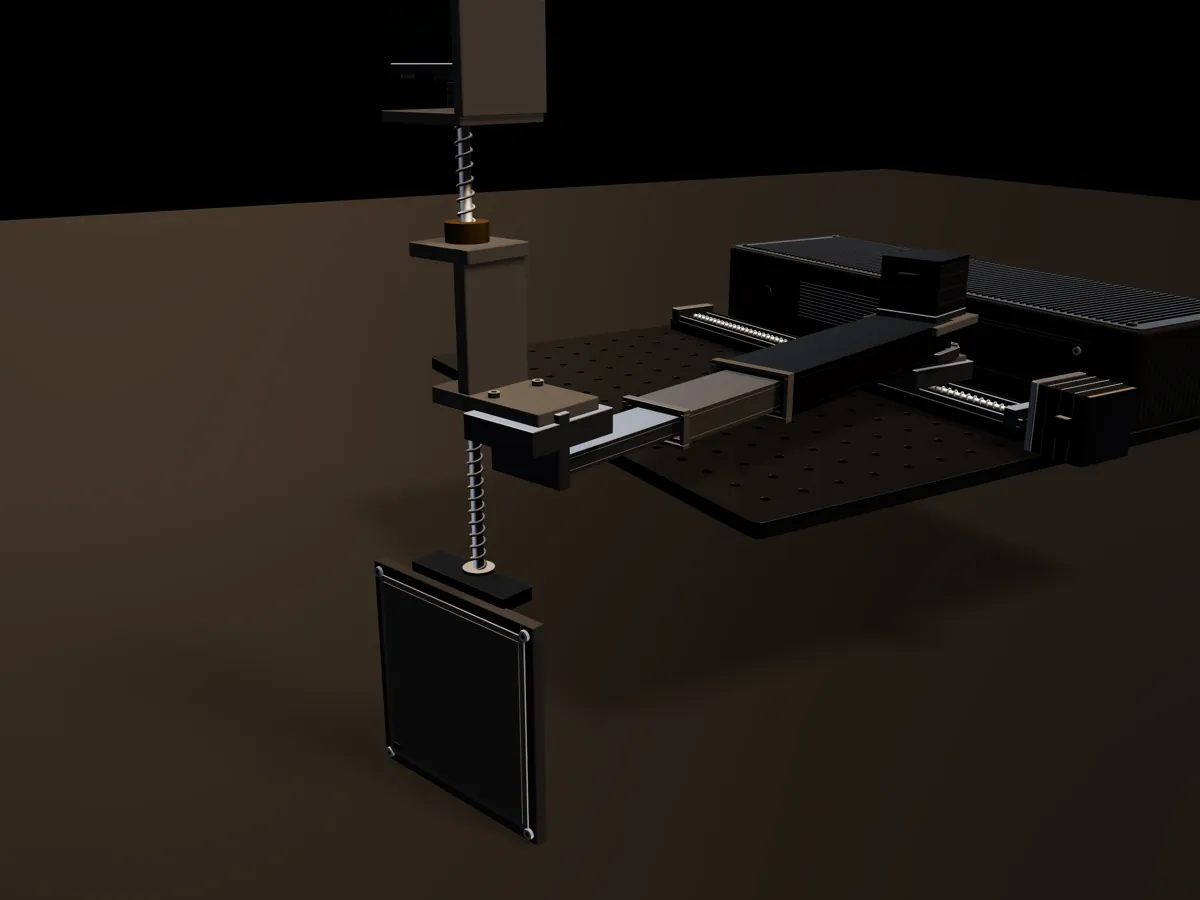
Mechanism and controls
Engineering capstone
Engineering capstone
Payload
A remote-controlled robot that places an X-ray detector panel for a bomb squad.
Aim
Place the detector panel without a person walking up to the emitter. Team targets: under $2,000 in materials, 3 hours of runtime, under 10 minutes of setup.
Tools
- CAD and rendering
- Arduino and Raspberry Pi controls
- Lead screws and linear actuators
- Handheld radio controller
Skills
- Mechanism design
- Embedded controls
- Wireless control
- Designing for a field user
Outcome
A four-axis deployment robot with a handheld controller, presented at the capstone trade show.
Detail
Open-source and built for the Bethlehem Bomb Squad's NOVO-DR emitter series.
Mechanism
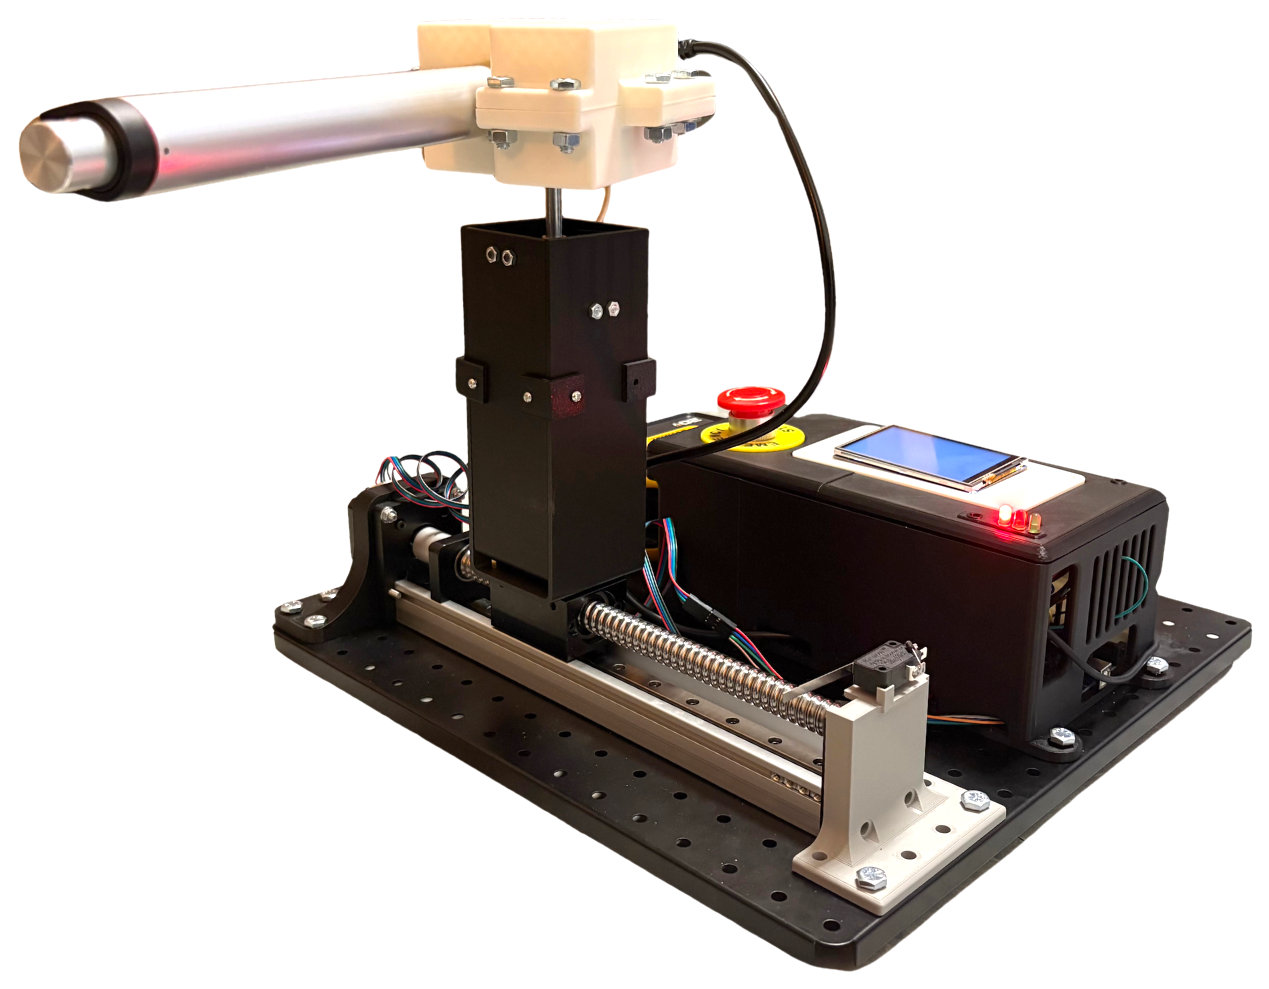
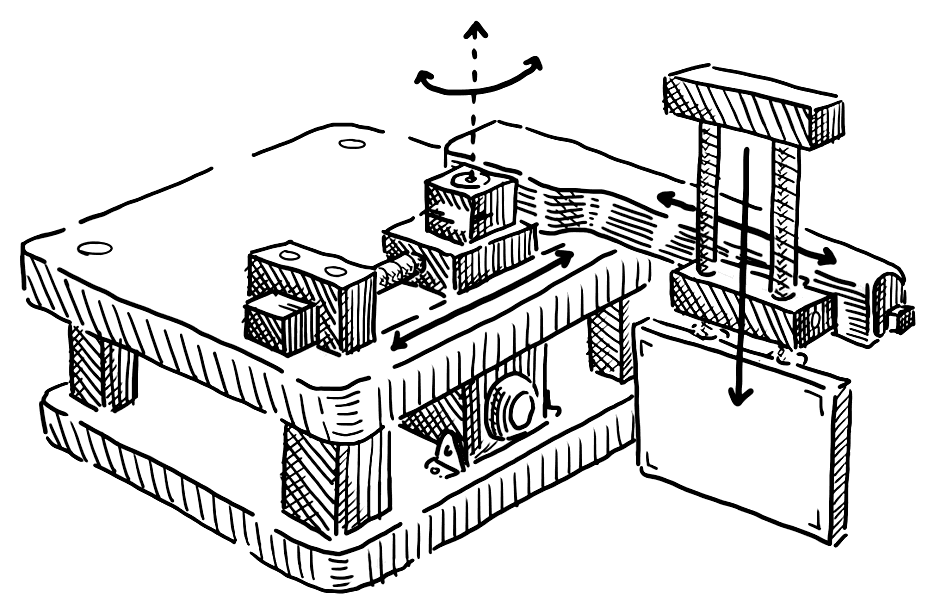
Lead-screw X rail, linear-actuator Y arm, yaw drive, and a Z lead screw ending in a French-cleat end effector.
Team
Kelly Carroll, Eliana Lo, Paige Klinetop, Patrick Tillinghast. Advisor Brian Slocum. Sponsor Capt. Lucas Fuller.
Available for DFMA, industrial design, and mechanical implementation.
Inquirejr@smartflowinventory.com